Category Archives: Retro Computing

Interfacing assembly with BASIC via DEFUSR, part 3

See also: part 1, part 2, part 3, part 4, part 5, part 6, part 7 and part 8.

A quick update on some code listed in the previous installment. I mentioned that the user was passing in an integer that represented which character (a byte) the screen would be cleared to. It would be passed in as a 16-bit value (register D). Since the screen characters were one byte, a check was added in case the value passed in was larger than 255 (cmpd #255).

In the comments, Justin chimed in:

You could also just do a clra to force the issue and avoid the compare and branch. – Justin

Justin’s suggestion would make the code smaller and ignore the first byte of register D. Thus, if the user did pass in anything higher, it would just chop off the excess. In binary, if the user passed in a value from 0-255, only bits would be set in register B. When the value was larger than 255, it would start setting bits in register A:

     Reg A     |     Reg B
0 0 0 0 0 0 0 0|0 0 0 0 0 0 0 0 = Reg D is 0
0 0 0 0 0 0 0 0|0 0 0 0 0 0 0 1 = Reg D is 1
0 0 0 0 0 0 0 0|1 1 1 1 1 1 1 1 = Reg D is 255
0 0 0 0 0 0 0 1|0 0 0 0 0 0 0 0 = Reg D is 256

If we just “clra”, we ensure the routine will never get a value greater than 8-bits. However, the user will get unexpected results. If they tried to pass in 256 (see above), register A would be cleared, and the value the routine would use would be 0. “Garbage in, garbage out!”

However, if error checking is desired, we still need to do a compare. L. Curtis Boyle suggested:

You could use TSTA. instead of CMPA #$00 to save a byte. – L. Curtis B.

I looked up the TST instruction, and it seems to test a byte in memory location or the A or B register and set some condition code register (CC) bits. If the high bit 7 is set, the CC register’s N bit will be set (testing for a negative value). If any bits are set, the CC register’z Z (zero) bit will be set (not zero). Hopefully I have that correct. The key point here is you can use TST to check for zero, and TSTA is a smaller instruction than CMPD. Here is the code:

* CLEARX.ASM v1.01
* by Allen C. Huffman of Sub-Etha Software
* www.subethasoftware.com / alsplace@pobox.com
*
* 1.01 use TSTA instead of CMPD per L. Curtis Boyle
*
* DEFUSRx() clear screen to character routine
*
* INPUT: ASCII character to clear screen to
* RETURNS: 0 is successful
* -1 if error
*
* EXAMPLE:
* CLEAR 200,&H3F00
* DEFUSR0=&H3F00
* A=USR0(42)
* PRINT A
*
ORGADDR EQU $3f00

GIVABF EQU  $B4F4  * 46324
INTCNV EQU  $B3ED  * 46061

       org  ORGADDR
start  jsr  INTCNV * get passed in value in D
       cmpd #255   * compare passed in value to 255
       bgt  error  * if greater, error
                   * D is made up of A and B, so if
                   * A has anything in it, it must be
                   * greater than 255.
       tsta        * test for zero
       bne  error  * branch if it is not zero
       ldx  #$400  * load X with start of screen
loop   stb  ,x+    * store B register at X and increment X
       cmpx #$600  * compare X to end of screen
       bne  loop   * if not there, keep looping
       bra  return * done
error  ldd  #-1    * load D with -1 for error code
return jmp  GIVABF * return to caller

* lwasm --decb -o clearx2.bin clearx2.asm
* decb copy -2 -r clearx2.bin ../Xroar/dsk/DRIVE0.DSK,CLEARX2.BIN

When I build this in to a .BIN file, the original showed 37 bytes, and this version shows 34 bytes. Here are the hex bytes that were generated:

clearx.hex:
:103F0000BDB3ED108300FF2E0C8E0400E7808C06FD
:0B3F10000026F92003CCFFFF7EB4F474

clearx2.hex:
:103F0000BDB3ED4D260C8E0400E7808C060026F92B
:083F10002003CCFFFF7EB4F496

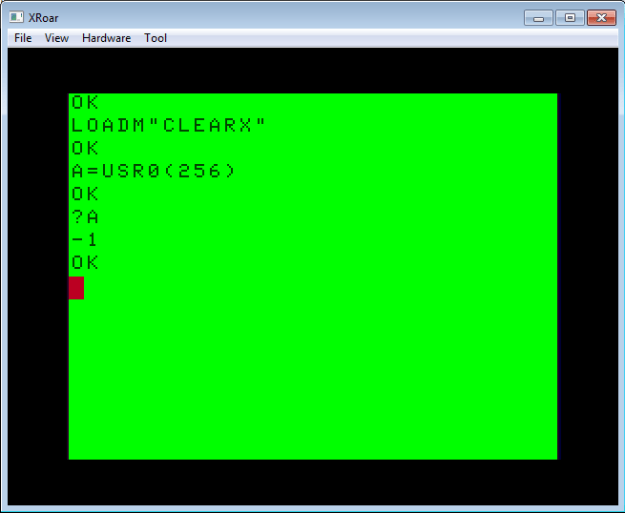
It appears to save three bytes. Curtis mentioned saving one byte which I think is the case between a “CMPA #0” and “TSTA”.

Best of all, with this change, it still works and rejects larger values:

CLEARX2: Electric Boogaloo

Thanks, Justin and Curtis, for those suggestions.

By the way, I know programmers often don’t bother with error checking. I mean, our code is perfect, right? And, clearing a screen is hardly anything that requires error checking. And while I agree, I noticed that even COLOR BASIC has error checking for it’s CLS command:

CLS with a value greater than 255 returns a Function Call error.

And, since the CoCo’s VDG chip supported nine colors, you only get colors for CLS 0 through CLS 8. If you try to clear to any value between 9 and 255, you get an easter egg:

CLS 9 through 255 present a Microsoft easter egg.

Bonus Question: There is also an additional CLS easter egg in the CoCo 3’s BASIC, Do you know what it is?

But I digress…

String Theory

You can really speed up a BASIC program by using assembly routines. For instance, while BASIC has great string manipulation routines, doing something simple like converting a string to uppercase can be painfully slow.

Suppose you were trying to write a text-based program and you wanted it to work on all Color Computer models. The original Color Computer 1 and early Color Computer 2 models could not display true lowercase – they displayed inverse characters instead. Later Tandy-branded CoCo 2s and the CoCo 3 could support lowercase.

To work on all systems, you might simply choose to put all your menu text in UPPERCASE. Or, you might store every string twice with an uppercase and mixed case version, and use a variable to know which one to print:

IF UC=1 PRINT "ENTER YOUR NAME:" ELSE PRINT "Enter your name:"

That would be one brute-force way to do it, but if your program used many strings, it would needlessly increase the size of your program. Instead, it might make sense to store all the strings in mixed case, and convert them to uppercase on output if needed.

Here is a very simple brute-force subroutine that does just this:

BASIC uppsercase subroutine.

And it works just fine…

Output of BASIC uppercase subroutine.

…but it’s slow. If no conversion is needed, the mixed case text instantly appears, but when conversion is needed, it crawls through the line character-by-character at speeds we haven’t seen text display at since the days of dial-up BBSes.

In an earlier series of articles, we discussed word-wrap routines in BASIC. Several folks contributed their versions, and we ranked them based on code size, RAM size and speed. There were many different approaches to the same thing, and the same applies to uppercasing a string, so please don’t take my brute-force example as the best way it can be done. It certainly isn’t, and can surely be improved.

But even the fastest BASIC routine won’t compare to doing the same thing in assembly.

Unfortunately, the USRx() command only allows you to pass in a numeric value, and not a string, so we can’t simply do something like:

A$=USR0("Convert this to all uppercase.") 'THIS WILL NOT WORK!

Pity. But, I was able to find the solution, and it involves another BASIC command known as VARPTR. This command gets the address of a variable in memory. You may recall that Darren Atkinson (creator of the CoCoSDC interface) used VARPTR in his version of the word-wrap routine:

This is our solution to passing in a string to USRx(). We can pass in the address of the string, and then the assembly code can figure it out from there. Here is how it works:

A$="This is a string in memory"
X = VARPTR(A$)
PRINT "A$ IS LOCATED AT ";X

If you run that code, you will see the address of that string in memory. We just need to understand how a string is stored.

The address does not point to the actual string data. Instead, it points to a few bytes of information that describe the string and where it is.

The first byte where the string is stored will be the size of that string:

A$="THIS IS A STRING IN MEMORY"
X = VARPTR(A$)
PRINT "A$ IS LOCATED AT";X
PRINT "A$ IS";PEEK(X);"LONG"

I forget what the second byte is used for, but bytes three and four are the actual address of the string character data:

PRINT "STRING DATA IS AT";PEEK(X+2)*256+PEEK(X+3)

On my system, it looks like this:

VARPTR of a string.

Once you know the actual starting place for the string data, you can see what that is in memory. In my case, the string length was 26 bytes, and the data started at 32709. I could use a FOR/NEXT loop and display the contents of that memory:

VARPTR string data example.

You will notice that the string information (length of string, location of string characters) is nowhere near the actual string data is. This is because the string characters could actually be in your program code, rather than in string memory. For example:

10 A$="THIS STRING IS IN THE PROGRAM"

Somewhere in RAM will be a string identification block with the length of the string and an address that points inside the program space. This makes it sort of an “embedded string” that lives inside your program. However, if you manipulate this string, BASIC will then make a copy of it in other memory and make the pointer go there. Thus, if you have a 10 character string like this:

10 A$="1234567890"

…and inside your code you do something like this:

20 A$=A$+"!"

…at that point, BASIC will no longer be pointing A$ to inside your code. It will be copied (pluy the “!”) to a new memory location inside of string space:

10 A$="1234567890"
20 GOSUB 1000
30 A$=A$+1
40 GOSUB 1000
50 END
1000 X=VARPTR(A$)
1010 PRINT"VARP:";X
1020 PRINT"SIZE:";PEEK(X)
1030 PRINT"LOC :";PEEK(X+2)*256+PEEK(X+3)
1040 PRINT
1050 RETURN

Here you can see that the location of the string (initially inside the program code space) moves to higher string memory RAM:

VARPTR shows you where the string moves to.

You won’t see memory decrease when this happens, because print MEM is showing you available program space. Strings live in a special section at the end of program memory. You may have seen the CLEAR command uses to reserve space for strings like this:

CLEAR 200

I believe 200 is the default if you don’t specify. In this case, the string started out inside the program’s code space and was not using any of that 200 bytes, and then after altering the string, it was copied in to the 200 bytes of string space.

Thus, if you want to see the impact, try running with “CLEAR 0” so there is NO ROOM for strings!

5 CLEAR 0 ' NO STRING SPACE

Now when we run that program, we see that the initial string works, because it is stored inside the program space, but the moment we try to add one character to it, there is no string memory available to copy the string to and it fails with an ?OS ERROR (out of string space).

?OS ERROR showing strings move from code space to string space.

This is something to be aware of if you are ever writing large programs with many strings. Rather than do something like this:

10 A$="[DELTA BBS]"
20 B$="MAIN MENU"
30 C$=" >"
40 PR$=A$+B$+C$:PRINT PR$

…which would then allocate string space to hold the length of A$, B$ and C$, you could keep those strings in program code space by just printing them out each time:

40 PRINT A$;B$;C$

The trick is to avoid BASIC having to allocate string memory and copy things over. If you need to do this, you can re-use a temporary string:

40 TS$=A$+B$+C$:GOSUB 1000:TS$=""

I think something like that would create a temporary string (TS) and copy all those code space strings over, then you could use it, and then setting it back to “” at the end would release that memory. If string memory is limited, tricks like this can really help out.

But I digress.

Now that we know how strings are stored, we can create an assembly routine that will serve as a UPPERCASE PRINT command.

Our assembly routine will be passed the address of the string, and then use byte 1 to get the length, and bytes 3 and 4 to get the location of the actual string characters. We can then walk through that memory and use the CHROUT ROM routine to output each character one-by-one, the same way BASIC does for PRINT.

Here is the routine:

* UCASE.ASM v1.00
* by Allen C. Huffman of Sub-Etha Software
* www.subethasoftware.com / alsplace@pobox.com
*
* DEFUSRx() uppercase output function
*
* INPUT: VARPTR of a string
* RETURNS: # chars processed
*
* EXAMPLE:
* CLEAR 200,&H3F00
* DEFUSR0=&H3F00
* A$="Print this in uppercase."
* PRINT A$
* A=USR0(VARPTR(A$))
*
ORGADDR EQU $3f00
dir
GIVABF EQU   $B4F4    * 46324
INTCNV EQU   $B3ED    * 46061
CHROUT EQU   $A002

       org   ORGADDR
start  jsr   INTCNV   * get passed in value in D
       tfr   d,x      * move value (varptr) to X
foo    ldb   ,x       * load string len to B
       ldy   2,x      * load string addr to Y
       beq   null     * exit if strlen is 0
       ldx   #0       * clear X (count of chars conv)
loop   lda   ,y       * load char in A
       cmpa  #'a      * compare to lowercase A
       blt   nextch   * if less, no conv needed
       cmpa  #'z      * compare to lowercase Z
       bgt   nextch   * if greater, no conv needed
lcase  suba  #32      * subtract 32 to make uppercase
       leax  1,x      * inc count of chars converted
nextch jsr   [CHROUT] * call ROM output character routine
       leay  1,y      * increment Y pointer
cont   decb           * decrement counter
       beq   exit     * if 0, go to exit
       bra   loop     * go to loop
exit   tfr   x,d      * move chars conv count to D
       bra   return   * return D to caller
null   ldd   #-1      * load -2 as error
return jmp   GIVABF   * return to caller

* lwasm --decb -o ucase.bin ucase.asm
* decb copy -2 -r ucase.bin ../Xroar/dsk/DRIVE0.DSK,UCASE.BIN

W will call our assembly routine like this:

A$="Convert this to uppercase."
A=USR0(VARPTR(A$))

And it should work on upper and lowercase strings automatically:

Uppercase output routine in assembly.

Now our uppercasing output routine is lightning fast.

To be continued…

Interfacing assembly with BASIC via DEFUSR, part 2

See also: part 1, part 2, part 3, part 4, part 5, part 6, part 7 and part 8.

Previously, we took a look at using the EXTENDED COLOR BASIC DEFUSR command to interface a bit of assembly language with a BASIC program. The example I gave simply added one to a value passed in:

Using DEFUSR to call assembly from BASIC.

That’s not very useful, so let’s do something a bit more visual.

One of my favorite bits of CoCo 6809 assembly code is this:

      org  $3f00
start ldx  #$400 * load X with start of 32-column screen
loop  inc  ,x+   * increment whatever is at X, then increment X
      cmpx #$600 * compare X with end of screen
      bne  loop  * if not end, go back to loop
      bra  start * go back to start

This endless loop will start incrementing every byte on the screen over and over making a fun display. I ran this code in the Mocha emulator (which has EDTASM available):

http://www.haplessgenius.com/mocha

Then I compiled it (“A/IM/WE/AO” – assemble, in memory, wait for errors, absolute origin – how can I still remember this???), and ran it in the debugger (“Z” for debugger, then “G START” to start it):

Mocha emulator running silly screen code.

This inspired me to make a small assembly routine to do something similar from BASIC. The CLS command can take an optional value (0-8) to specify what color to clear the screen to. Let’s make an assembly routine that will allow specifying ANY character to clear the screen to:

ORGADDR EQU $3f00

GIVABF EQU  $B4F4  * 46324
INTCNV EQU  $B3ED  * 46061

       org  ORGADDR
start  jsr  INTCNV * get passed in value in D
       cmpd #255   * compare passed in value to 255
       bgt  error  * if greater, error
       ldx  #$400  * load X with start of screen
loop   stb  ,x+    * store B register at X and increment X
       cmpx #$600  * compare X to end of screen
       bne  loop   * if not there, keep looping
       bra  return * done
error  ldd  #-1    * load D with -1 for error code
return jmp  GIVABF * return to caller

First, I added a bit of error checking so if the user passed in anything greater than 255, it will return -1 as an error code. Otherwise, it returns back the value passed in (that the screen was cleared to.)

Side Note: Hmmm. Since I know register D is register A and B combined, all I really need to do is make sure A is 0. i.e, “D=00xx”. If anything is in A, it is greater than the one byte value in B. I suppose I could also have done “cmpa #0 / bne error”. Doing something like that might be smaller and/or faster than comparing a 16-bit register. Anyone want to provide me a better way?

Since the 16-bit register D is made up of the two 8-bit registers A and B, I can just use B as the value passed in (0-255).

Here is what it would do with a bad value:

Clear X routine, bad value error.

And here is it with a valid value of 42:

Clear X with a value of 42.

So far so good.

In the next part, we’ll look at how to pass in a string instead of an integer.

Interfacing assembly with BASIC via DEFUSR, part 1

See also: part 1, part 2, part 3, part 4, part 5, part 6, part 7 and part 8.

This article series will demonstrate how to interface some 6809 assembly code with Microsoft BASIC on a Tandy/Radio Shack TRS-80 Color Computer.

BASIC on the Color Computer is easy, but not fast. 6809 assembly language is fast, but not easy. Fortunately, it’s easy (and fast?) to combine them, allowing you to write a BASIC program that makes use of some assembly language to speed things up.

Assembly code can be loaded (or POKEd) in to memory at a specific address and then invoked by the EXEC command. This is fine for a “go do this” type of routine. But, if you want the assembly code to interact with BASIC by returning values or modifying a variable or string, you can use a special BASIC command designed for this purpose.

The Color Computer’s original 1980 COLOR BASIC had a USR command which could be used to call an assembly language routine via a BASIC interface. From the Wikipedia entry:

USR(num) calls a machine language subroutine whose address is stored in memory locations 275 and 276. num is passed to the routine, and a return value is assigned when the routine is done

This allowed passing a numeric parameter in to the assembly routine, and getting back a status value.

When EXTENDED COLOR BASIC came out, USR was enhanced to allow defining multiple routines. It looks like this:

DEFUSR0=&H3F00
A=USR0(42)

That code would define USR0 to call an assembly routine starting at memory location &H3F00 and pass it the value of 42. That routine could then return a value back to the caller which would end up in the variable A.

There are two ROM routines that enable receiving a value from BASIC, and returning one back:

  1. INTCNV will convert the integer passed in the USRx() call and store it in register D.
  2. GIVABF will take whatever is in register D and return it to the USR0() call.

Here is a very simple assembly routine that would receive a value, add one to it, and return it.

ORGADDR EQU $3f00

GIVABF EQU $B4F4   * 46324
INTCNV EQU $B3ED   * 46061

       org  ORGADDR
start  jsr  INTCNV * get passed in value in D
       tfr  d,x    * transfer D to X so we can manipulate it
       leax 1,x    * add 1 to X
       tfr  x,d    * transfer X back to D
return jmp  GIVABF * return to caller

Using the lwtools 6809 cross compiler, I can compile it in to a .BIN file that is loadable in DISK BASIC:

lwasm --decb -o addone.bin addone.asm

I could then use the toolshed decb command to copy the binary to a .DSK image to run in an amulator such as Xroar. In my case, I have an image called DRIVE0.DSK I want to copy it to:

decb copy -2 -r addone.bin ../Xroar/dsk/DRIVE0.DSK,ADDONE.BIN

Now I can run the Xroar emulator and mount this disk image and test it:

Using DEFUSR to call assembly from BASIC.

It works! Of course, I could have just done…

A=A+1

…so maybe this isn’t the best use of assembly language. ;-)

Up next … a look at doing something actually useful.

Building KenTon/LR-Tech SCSI drivers for NitrOS-9

While the NitrOS-9 project does contain drivers for the KenTon and LR-Tech hard drive interfaces, they are not built or included by default. I wanted to document the steps I took to build and use the KenTon interface under the current NitrOS-9.

Basically, you will be modifying a few makefiles to enable the building of the low level booter, device drivers and device descriptors. If I recall, the changes are the same for each of these makefiles, but you only need to make them for the one you are using. If you are only using the KenTon drivers under NitrOS-9 Level 2 on a CoCo 3, just do that makefile.

  • nitros9/level1/coco1/modules/makefile
  • nitros9/level2/coco3/modules/makefile
  • nitros9/level3/coco3/modules/makefile

Step 1 – Add “KTLRFLAGS”.

These generate the define used inside the generic SCSI source code so it knows which code to build.

TC3FLAGS = $(AFLAGS) -DTC3=1 $(FLAGS)
KTLRFLAGS = $(AFLAGS) -DKTLR=1 $(FLAGS)
IDEFLAGS = $(AFLAGS) -DIDE=1 $(FLAGS)

Step 2 – Add “boot_ktlr” to the BOOTER list.

This makes it a dependency so make will look for it and try to build it. I added it in the middle of the list so when you get updates, it will be easier for the “diff” tool to see what has changed.

BOOTERS = boot_1773_6ms boot_1773_30ms \
 boot_burke boot_rampak boot_wd1002 boot_dw \
 boot_tc3 boot_ide boot_rom boot_dw_becker \
 boot_ktlr \
 boot_dw_arduino boot_dw_38400 boot_sdc

Step 3 – Add the modules to the RBF list.

RBF = rbf.mn \
 rbdw.dr dwio.sb dwio_38400.sb dwio_becker.sb dwio_arduino.sb \
 rb1773.dr rb1773_scii_ff74.dr rb1773_scii_ff58.dr \
 ddd0_35s.dd d0_35s.dd d1_35s.dd d2_35s.dd d3_35s.dd \
 ddd0_40d.dd d0_40d.dd d1_40d.dd d2_40d.dd \
 ddd0_80d.dd d0_80d.dd d1_80d.dd d2_80d.dd \
 ddx0.dd x0.dd x1.dd x2.dd x3.dd \
 rbsuper.dr lltc3.dr llide.dr llcocosdc.dr \
 llktlr.dr \
 dds0_ktlr.dd s0_ktlr.dd s1_ktlr.dd s2_ktlr.dd s3_ktlr.dd s4_ktlr.dd \
     s5_ktlr.dd s6_ktlr.dd sh_ktlr.dd \
 ddi0_ide.dd i0_ide.dd i1_ide.dd ih_ide.dd \
 dds0_tc3.dd s0_tc3.dd s1_tc3.dd s2_tc3.dd s3_tc3.dd s4_tc3.dd \
     s5_tc3.dd s6_tc3.dd sh_tc3.dd \
 ddsd0_cocosdc.dd sd0_cocosdc.dd sd1_cocosdc.dd

Step 4 – Add the dependency to build the driver:

# TC^3 SCSI Booter
boot_tc3: boot_scsi.asm
 $(AS) $(ASOUT)$@ $< $(TC3FLAGS)

# KenTon/LR-Tech SCSI Booter
boot_ktlr: boot_scsi.asm
 $(AS) $(ASOUT)$@ $< $(KTLRFLAGS)
 
# SuperIDE/Glenside IDE Booter
boot_ide: boot_ide.asm
 $(AS) $(ASOUT)$@ $< $(IDEFLAGS)

Step 5 – Add the dependencies for building each descriptor. I put mine after the existing TC3 SCSI driver stuff:

sh_tc3.dd: superdesc.asm
 $(AS) $(ASOUT)$@ $< $(TC3FLAGS) $(HDBDOS)

# KenTon/LR-Tech SCSI Descriptors
dds0_ktlr.dd: superdesc.asm
 $(AS) $(ASOUT)$@ $< $(KTLRFLAGS) $(ID0) -DDD=1

s0_ktlr.dd: superdesc.asm
 $(AS) $(ASOUT)$@ $< $(KTLRFLAGS) $(ID0) $(SCSI_HD)

s1_ktlr.dd: superdesc.asm
 $(AS) $(ASOUT)$@ $< $(KTLRFLAGS) $(ID1) $(SCSI_HD)

s2_ktlr.dd: superdesc.asm
 $(AS) $(ASOUT)$@ $< $(KTLRFLAGS) $(ID2) $(SCSI_HD)

s3_ktlr.dd: superdesc.asm
 $(AS) $(ASOUT)$@ $< $(KTLRFLAGS) $(ID3) $(SCSI_HD)

s4_ktlr.dd: superdesc.asm
 $(AS) $(ASOUT)$@ $< $(KTLRFLAGS) $(ID4) $(SCSI_HD)

s5_ktlr.dd: superdesc.asm
 $(AS) $(ASOUT)$@ $< $(KTLRFLAGS) $(ID5) $(SCSI_HD)

s6_ktlr.dd: superdesc.asm
 $(AS) $(ASOUT)$@ $< $(KTLRFLAGS) $(ID6) $(SCSI_HD)

sh_ktlr.dd: superdesc.asm
 $(AS) $(ASOUT)$@ $< $(KTLRFLAGS) $(HDBDOS)

# IDE Descriptors
ddi0_ide.dd: superdesc.asm
 $(AS) $(ASOUT)$@ $< $(IDEFLAGS) $(MASTER) -DDD=1

Now those modules should be built and made available for including in your bootfile. You could do this by editing the bootlist you are using:

  • nitros9/level1/coco1/bootlists/standard.bl
  • nitros9/level2/coco3/bootlists/standard.bl
  • nitros9/level3/coco3/bootlists/standardL3.bl

Or you could use a bootfile editor like ezgen to add them to your current bootfile. Or, if you were just doing something temporary (like I was, to pull data from hard drives), you could just merge the needed modules together and dynamically load them when you need to use the SCSI drive.

Hopefully this will be helpful to someone else.

CoCoSDC SDC-DOS version 1.14 release

In case you missed it, in December 2016, a software update to CoCoSDC and SDC-DOS was released. You can find it under “Latest Firmware” on this page:

http://cocosdc.blogspot.com/

SDC-DOS is now up to version 1.14 and includes the following changes:

  1. AUTOEXEC. If “AUTOEXEC.BAS” if found on a mounted disk image, it will automatically run on startup. Holding down SPACE on startup will bypass this. (I think Kenton’s RGB-DOS did this?)
  2. EXP. A new “EXP” command has been added. It will mount an image called “SDCEXP.DSK” and, if present, run “AUTOEXEC.BAS” from that image.
  3. DEF DW. You can now specify DriveWire baud rates.
  4. WRITE/COPY MEM. These commands can now write to flash pages $FExx on a CoCo 3.
  5. RUN @bank. Code to select and execute one of the virtual ROM banks has been rewritten to make it more compatible with various ROMs.
  6. DSKINI. Fixes a bug where drive motor could remain on when using a CoCoSDC and a real floppy controller at the same time.

The update comes with a .DSK image that you mount and then run a utility which will take care of the upgrade.

Nice! I just started setting my CoCo system back up, and will be trying this out soon.

Commodore Amiga documentary

I just found this Commodore Amiga documentary on HULU and watched it last night. You can find more information on the official website:

https://amigafilm.com

For those too young to remember, the Amiga was the most advanced home computer ever sold. It was incredibly ahead of its time, especially compared to any of the competing systems that were sold when it was released in 1985.

Us old timers recall the early days of home computer with systems like the Apple 2, Commodore PET, Atari 400/800, and TRS-80. There were many other systems, like the Timex Sinclair ZX81, Texas Instruments TI99, VIC-20 and then the massively popular Commodore 64 (and later less successful 128). Thanks to the internet, I have learned about dozens of other competing systems that I never even heard of back then.

The next generation of computers were things like the 1984 Apple Macintosh and the Atari ST. The Commodore Amiga blew everything out of the water. It had multitasking and amazing color graphics (back when a PC produced only 4 awful colors on a “high resolution” screen). It had 4-channel STEREO digital sound. It was just amazing.

I recall seeing an Atari ST in a shop in Houston, and really wanting one, but it was just too expensive. Sure, my CoCo setup ended up costing way more as I added more and more components, but I could do all of that gradually. The entry level cost of an Atari ST (or Amiga) and the required monitor was simply out of my price range.

But I had Commodore 64 friends that moved on to the Amiga, and I remember getting to see one of the first time (probably in late 1987). The bouncing ball demo brought tears to my eye. I had simply never seen anything like that on a home computer screen.

This documentary gives some of the background of the creation of the Amiga, and how it ended up at Commodore (and almost ended up at Atari).

It’s a fascinating look at what was truly an amazing piece of hardware.

The movie is streaming on HULU if you have a subscription, and can be rented or bought on many other services. I recommend it, though I wish it were about 10-15 minutes longer so it could give a more complete timeline of the various models that came out and why they were created (especially things like the CDTV and CD32).

Enjoy…

Creating a RaspberryPi DriveWire server

  • 2016/05/12 – This is a work-in-progress article I originally wrote on February 8, 2015, but never completed. The other night I was trying to look up my notes to help Curtis B. with a NitrOS-9 boot disk and I realized I never completed this. I will try to finish it when I have a moment.

Summary

To get DriveWire 4 server running on a Raspberry Pi, you will do the following:

  1. Download the DriveWire server to the Pi and unzip it:
    wget http://sites.google.com/site/drivewire4/download/DriveWire4_4.3.3.zip
    unzip DriveWire4_4.3.3.zip
    cd DriveWire4_4.3.3.zip
  2. Edit the config.xml file to default to your serial port on your Pi in <deviceType> and <serialDevice>. (i.e., “serial” and “/dev/ttyUSB0“)
  3. Run the server with no user interface:
    java -jar DW4UI.jar -noui
  4. On the CoCo, load the needed DriveWire modules from NITROS9/6x08L2/MODULES/RBF:
    dwio.sb, rbdw.dr, x0.dd up to x3.dd
  5. Use the “dw” command to test things by creating a blank disk image:
    dw disk create 0 /home/pi/test.dsk
    format /x0
    dir /x0
  6. Customize your boot disk to include the modules you want and read the documentation to learn how to use all the cool virtual terminals, MIDI and other neat features.

And now, the long version…

Materials Needed

  1. Raspberry Pi B (or B+, or probably the Pi 2 B). I did all these steps on a B.
  2. USB keyboard (a mouse makes things easier, but I do not have one so all of these tips will just use a Pi, keyboard and HDMI TV/monitor).
  3. Compatible* 8GB SD card (or larger).
  4. Ethernet cable to hook the Pi to the Internet. (Required if you plan to do the network install of NOOBS LITE).
  5. WiFi (with a supported USB dongle) or Ethernet is needed later for downloading the DriveWire software and updates, but there are ways to do all of this without any Internet access if you start with the full NOOBs installer.
  6. Compatible* USB serial adapter (or TTL->RS232 converter for use with the built in UART pins of the Pi).
  7. …

Preparation on Windows/Mac/Linux

  1. Download the “NOOBS” installation for Raspberry Pi (currently 1.3.12). You can get the full NOOBS (780MB, just unzip and copy to the SD card and boot), or the NOOBS LITE (22.8MB) version.
    • NOOBS LITE can also be used. It is a much smaller download, but requires the Pi to be hooked up to the internet via Ethernet to download the rest of the OS files which is about 2355MB.
      http://www.raspberrypi.org/downloads/
  2. Unzip the files, then copy them over to a freshly formatted SD card.

Preparation on the Raspberry Pi

  1. Boot the Pi using this card. You will see a menu of operating systems you can install. Choose “Raspbian [RECOMMENDED]” at the top by using the arrow keys and SPACE to select. You may also wish to hit “l” for Language and set it to “English (US)” or your preference, and “9” for Keyboard and select yours. Once Raspbian is selected, press “I” for install. It will ask if you are sure you wish to overwrite the SD card. Select “Y” for yes.
    • NOOBS LITE: The Pi will then download the Raspbian image (2.3GB), then install.
    • NOOBS: The Pi will then install.
  2. The Pi will (eventually) reboot and after a bit, you get a DOS-like screen for the raspi-config utility. Arrow over to Finish and press ENTER. You will not be at the Pi shell prompt.
    pi@raspberrypi ~ $
  3. At this point, I like to do a full reboot to make sure everything is working properly:
    sudo reboot
  4. On a reboot, you won’t go directly to a shell prompt. You will get a login prompt. The default account is:
    username: pi
    password: rasbperry.
    Log in and you will get back to the shell prompt. You will be in the home directory for user “pi”.
  5. Now we need to download the DriveWire 4 software. Note the filename will change when DriveWire is updated, so check the official site if this does not work.
    wget http://sites.google.com/site/drivewire4/download/DriveWire4_4.3.3.zip
  6. After the zip file is download, you can extract it by typing:
    unzip DriveWire4_4.3.3.zip
  7. DriveWire 4 is set up to run with a nice GUI with mouse control. This requires a keyboard and mouse, and the Pi to be set up with X-Windows running. Since I do not have a mouse, and plan to run the Pi headless with nothing hooked up to it but power and the CoCo, this is not an option for me. Instead, I need to manually edit the configuration file to tell it what Linux serial port I will be using.
    cd DriveWire4_4.3.3
    copy config.xml config.xml.org (always keep a backup!)
    pico config.xml

    The editor will open, and you want to look for a few entries:<instance category=”instance” desc=”Autocreated 2013-03-24 23:57:53.831″ name=”TCP connection via TCP“>
    …
    <DeviceType category=”device” list=”serial,tcp-server,tcp-client,dummy” type=”list”>tcp-server</DeviceType>
    …
    <SerialDevice category=”device” type=”serialdev”>COM14</SerialDevice>The first entry is just the name of the connection. You could change that to “Serial Connection” or whatever. The second “tcp-“server” should be changed to “serial”, and the “COM14” entry should be changed to your serial port device. On my Pi, when I plug in a single USB RS232 adapter, it shows up as /dev/ttyUSB0 so that is what I use.
  8. Save your changes back to the file (Ctrl-X, Y) and now you are ready to run the server without a user interface. (Getting the user interface to run requires installed two more additional packages, and I will make a tutorial for that soon, if anyone wants me to.)
    java -jar DW4UI.jar -noui
  9. After a bit, Java will load and the DriveWire 4 server will start. Java is big, and the Pi is small, so it can be quite sluggish. Now, with the USB cable connected between the Pi and the CoCo, you can start testing.

Preparation on NitrOS-9

This tutorial is being written for someone who already has an active NitrOS-9 system and wants to add DriveWire support to it. If you have no customized

If you are using one of the default NitrOS-9 disk images for you system, it should have a NITROS9 directory, and inside of it will be various device drivers and descriptors, including the ones used by DriveWire. Ultimately, you would want to make a custom boot disk that includes these modules, but here is a simple way to merge them together and just load them when you want to use them. From OS-9:

  1. If you are running a stock CoCo 3 with the standard 6809 processor, go here:
    cd /dd/NITROS9/6809L2/MODULES

    …and if you have upgraded your CPU with a Hitachi 6309, go here:
    cd /dd/NITROS9/6309L2/MODULES
  2. The modules you want depend on what you plan to do. Here is the list:
    • drio.sb – this module handles all communication with the DriveWire server.
    • rbdw.dr – RBF device driver that uses DriveWire for disk access instead of disk hardware
      • ddx0.dd, x0.dd, x1.dd, x2.dd, x3.dd – device descriptors for the DriveWire disk drives (/x0 to /x3, with ddx0.dd being a /dd descriptor for DriveWire).
    • scdwp.dr – printer driver
      • p_scdwp.dd – device descriptor /p for scdwp.dr
    • scdwv.dr – virtual serial port driver
      • n_scdwv.dd, n1_scdwv.dd to n13_scdwv.dd – serial port descriptors. /n is the “next available” descriptor, similar to /w for windows. /n devices may also be used for MIDI.
      • midi_scdwv.dd – this is n14 but named /midi for MIDI programs that are hard coded to look for that name.
      • term_z_scdwv.dt, z1_scdwv.dd to z7_scdwv.dd – (??? not in the doc wiki)
  3. For my example, I am only concerned about the disk drives, so I would merge the following modules together:
    chd RBF
    merge dwio.sb rbdw.dr x0.dd x1.dd x2.dd x3.dd >/dd/dw
    This gives me a single file called “dw” I can load to get DW support instantly. First, I need to set the attributes to allow that:
    attr /dd/dw e
    …then I can just load it when I want to use DriveWire:
    load /dd/dw
  4. If this worked, you should now be able to use the DriveWire command, “dw”, to communicate with the server. Type “dw” and it should report back a list of commands:
    config  disk  log  midi  net  port  server
    …and you can then type “dw config” or “dw disk” to see what all it can do.

Using DriveWire

Here is an example of creating an empty disk image and formatting it:

dw create 0 /home/pi/test.dsk
format /x0
dir /x0

If you look on the Pi, you will see a new file “test.dsk” there. You can now use this disk like any other OS-9 disk. In my test, I copied my NITROS9 directory over to it just for fun:

chd /dd/NITROS9
dsave /x0 ! shell

DriveWire’s performance is not as good as you’d get from a No Halt floppy controller like the Disto Super Controller 2 or a hard drive interface like the Cloud-9 SuperIDE or KenTon SCSI. As disk activity is going on, interrupts are masked while data is blasted out of the bitbanger port. Still, it did a remarkable job keeping up with my typing. Quite impressive for a cheap cable and a $35 computer with a serial port.

TO DO

  1. Make the DriveWire 4 server auto-start.
  2. Update the DriveWire 4 software from the command line (is this even possible?).
  3. Update the Raspberry Pi software.

Problems

One issue I immediately ran in to was a bunch of ERROR #207 (Memory Full) errors. mfree still showed 352K free, and it wasn’t the #237 (RAM Full) that happens when there isn’t enough room left in the main 64K memory map.

Building NitrOS-9 on Mac OS X

Updates:

  • 6-22-2022 – I wrote up the steps on building LWTOOLS under Windows using Cygwin. I found it very simple. But, I was not able to get Toolshed building under Cygwin.
  • 12-7-2022 – A few updates about ‘hg’ on Mac.
  • 2-20-2025 – Updated location of NitrOS9 project, and changing instructions to use “git” instead of Mercurial for that step.

Since I have to relearn all the steps, I thought I would post them as I go through them. The NitrOS-9 website has a tutorial on building it, but here are my steps with some specifically for Mac OS X:

Install the Command Line Tools for Mac OS X.

We need the command line versions of the Mac OS X compiler so we can build the tools that are then used to build NitrOS-9. If you have XCODE installed, you may already have them. An easy way to do this is from a Terminal prompt:

xcode-select --install

That will launch the Apple Mac App Store installer and get the tools for you. Cool.

Installing the Mac OS X command line tools.
Screenshot 2016-05-01 17.26.21

Download Mercurial.

The NitrOS-9 repository now uses git as version control. You will need to download a git client, or use the GitHub Desktop app. I just learned about this change today (Feb 2025) so I need to update these steps.

Toolshed and LWTools use Mercurial, so you will need to download that as well. On macOS, you should be able to install it using “brew install mercurial”:

brew install mercurial

Download LWTools.

These are the cross-compiler tools used to build 6809 source code from Mac/Windows/Linux systems. From a Terminal prompt, find a directory you want to download the lwtools to. I chose a poor location — “CoCo” inside my Downloads folder:

pwd
/Users/allenh/Downloads/CoCo

From this directory, use the “hg” command to obtain and build the tools. It will build the directory you specify from the command line (“lwtools”):

hg clone http://lwtools.projects.l-w.ca/hg/ lwtools
cd lwtools
make
sudo make install
cd ..

Build Toolshed.

Next we want to build Toolshed. This is a series of command-line utilities that operate on CoCo/OS-9 disk images (like those used with emulators and the CoCoSDC interface). Once again, I do these steps from my “Downloads/CoCo” directory:

hg clone http://hg.code.sf.net/p/toolshed/code toolshed
cd toolshed
sudo make -C build/unix install
cd ..

(Note: I had to use “sudo make…” here to get it to build on my system.) The different build/make process shows the different styles of the various developers that made these tools. (Note: Mine seems to fail looking for a command “markdown” at the very end. Not sure what this is, but it seems to be building HTML documentation or something.)

Build NitrOS-9.

Now we are ready to download and build NitrOS-9. Once again, I start in my “Downloads/CoCo” directory, and issue the following git commands to download all the NitrOS-9 stuff:

git clone https://github.com/nitros9project/nitros9.git
cd nitros9
make dsk

This will build absolutely everything, including tons of ports and disk images you likely do not want. After this, you will have all the sources, and have built all (or some) of the sample disk images for various types of hardware (CoCo 1/2, CoCo 3, 6809 or 6309, CoCoSDC controller versus floppy or IDE hard drive, etc.).

If you are only interested in a CoCo 3 6809 setup, why build all the CoCo 1/2 and Dragon versions, or any of the 6309 stuff? I always build everything, but you can also specify to build just a specific port. For my CoCo 3/6309 build, I could do this instead:

make dsk PORTS=coco3_6309

For stock 6809 CoCo 3:

make dsk PORTS=coco3

Updating NitrOS-9 and the Tools.

Later, if you want to update your sources, you can use this command from the “nitros9” directory:

git pull
make ask

For updating LWTools and Toolshed, use this:

hg pull
hg update

…then the build steps, shown earlier.

NOTE: David Ladd has pointed out that you may want to clean out old files before rebuilding. For Toolshed, I needed to do this first:

hg pull
hg update
make -C build/unix clean
make -C build/unix

I do this occasionally to get the “latest and greatest.” You can do this for the other tools, too, by changing in to their directory then issuing the “pull” and “update”, then the appropriate make command.

TODO: This next section was from when NitrOS9 was at SourceForge and used Mercurial. I have not had a merge conflict using git yet, so I don’t know what those look like. I will try to update this document later.

If you get a merge conflict because you changed something locally, you might see this:

hg update
abort: outstanding merge conflicts

You can use this command to see what files have been changed on your local repository that conflict with the master files. This happens if, for instance, you tweak a makefile or build list or source code:

hg resolve -l
U 3rdparty/utils/tlindner/sdir.asm

This reminded me that I already Tim’s “sdir” source code (for CoCoSDC) so enable built in help and such. I have to revert those changes if I want to update, or learn how to use the merge too… I forgot!

These steps should get you everything you need to begin playing with NitrOS-9 on a real CoCo with the CoCoSDC interface, or an emulator. If you plan to use real floppies, you can use toolshed utilities to format and then copy disk image .DSK files over to the physical floppy, but I don’t have any way to hook a 360K Floppy drive to my Mac so I have never done this. CoCoSDC is the way to go there.

More to come…

25th annual “Last” Chicago CoCoFEST!

Tandy/Radio Shack TRS-80 Color Computer fans, take note. This weekend (April 23-24, 2016), the Glenside Color Computer Club will be hosting the 25th annual “Last” Chicago CoCoFEST! in Lombard, Illinois (near Chicago).

I attended the first “Last” CoCoFEST! there back in 1992, flying up from Lufkin, Texas with a CoCo friend of mine, Mark. That 1992 event was presented by Dave Myers of CoCoPro, and Glenside was the host club for it. Dave had gotten in to the CoCo convention scene in 1990 when he held his first CoCoFest in Atlanta, Georgia, with the Atlanta Computer Society as the host club there.

These CoCoFests were being started just as the long-running RainbowFests were winding down. Rainbow Magazine was the premier Color Computer publication, starting out as a photocopied newsletter and growing to a 300+ page monthly periodical. Rainbow had years where they held several events across America, but their last event was in Chicago in 1991.

Dave first stepped in to offer an event “down South” in 1990. Rainbow had held only one southern event in Ft. Worth, Texas. When the final RainbowFest was held, Dave decided to continue the tradition with a new event in its place.

Though CoCoPro would exit the convention scene after that 1992 event, the CoCo clubs continued. Atlanta Computer Society kept CoCoFests going there through 1995. The Glenside CoCo Club has continued to host events ever since the original CoCoPro event in 1992 (and they were host club for the RainbowFests before that). But this year is the last one. Again.

Dave chose the “Last” (in quotes) moniker for his first Chicago-area event knowing it could be the final event, and it become the “2nd annual ‘Last'” event the following year when Glenside took over.

Then the 3rd … and 4th … and 5th…

It’s hard to believe that was 25 years ago!

I last got to visit the CoCoFEST! in 2013. I would like to at least day trip to this one. Several long-time CoCo folks from the past are showing up (including our own monk, Brother Jeremy, and our Canadian pal L. Curtis Boyle). I have had several generous offers to provide lodging if I wanted to stay overnight, and even offers to fund my gas. These are some of the people I have called friends longer than just about anyone else I still have in my life.

If you can make it, and I am there, be sure to say hi. If I am not there, be sure to take photos and let me know what I missed.

Find out more: http://glensideccc.com/

Commodore VIC-20: My first computer.

My very first computer was a Commodore VIC-20. At the time, I think I was interested in a new video game system like an Intellivision. My dad suggested that, for about the same money, I could get a computer instead that would do more than just play games. (Second generation game systems like Intellivison or ColecoVision were around $200.)

My desired to get a home computer was also inspired by a guy I met in one of my 7th grade classes. My new friend, Jimmy J., had shared a book on BASIC computer programming with me. We would go down to a local Radio Shack and type in programs on their TRS-80 Model 3s.

My dad began researching options, and I did the same. I ended up choosing something called a VIC-20. I was disappointed when my dad told me he had chosen a different machine – something he called the Commodore. When I realized we were talking about the same machine, it seemed like the perfect choice.

The VIC-20 marketing campaign was “Why buy just a video game?” and “A real computer for the price of a toy.” This may have actually been what got my dad thinking about a home computer in the first place. It was described as “the wonder computer of the 1980s for under $300” and “the first honest-to-goodness full color computer you can buy for only $299.95”, or so claimed launch spokesman William “Captain Kirk” Shatner.

A TV commercial for it parodied the Intellivison and the Atari VCS ads with Shatner “beaming down” between the two saying “move over for my friend VIC”. How could you go wrong with the computer that the Captain of the U.S.S. Enterprise liked?

I received my new VIC-20 sometime in 1982. It was likely for my birthday in August.

I remember hooking it up to a small color TV I had, and staying up all night going through the manual and learning how to program “CBM BASIC V2” which had a whopping 3583 bytes of memory available. Since I had no way to save any programs I typed in, I had to leave the computer on all the time else I would lose all my work. The Commodore Dataset (their expensive and proprietary cassette player)  was about $75 at the time, and that was the first add-on I wanted. I still remember the problems I had with it, and that we had to exchange it at the store a few times (all with the same problem) until we figured out you just couldn’t use it on one side of the TV. There was too much electrical interference apparently.

Custom Programs Limited

My friend Jimmy also got his first computer around this time – a Timex Sinclair. Another friend of ours, whose name I forget, had access to TRS-80s at school. Somehow we got the idea that we could offer to create custom programs for people, and thus the idea of “Custom Programs Limited” was created.

CPU Software - my first "company" in 1982.
CPU Software – my first “company” in 1982.

Jimmy suggested we change it to “Unlimited” so the initials would be C.P.U. At the time, I don’t think I even knew the term “central processing unit.” And thus was born CPU Software.

I remember we came up with an idea for a horse racing game, and each of us created a version of it for our systems: VIC-20, TRS-80 and Timex Sinclair. I do not think we ever did much after that. We probably did not realize how big home computing would become. Had we seriously pursued this venture, maybe we could have all ended up rich and living on a private island somewhere.

I did write a series of games for the VIC-20, including one that was published in a newsletter called the VIC-NIC NEWS. I believe I was in the process of having some of my video games distributed through a cassette magazine called VIXEN (renamed to FOX 20 after their first issue), but I do not recall what happened with that. I know one of the programs they considered (Factory TNT, a graphically updated version of the one VIC-NIC published) they rejected after seeing my first version already published elsewhere.

I have created a special page listing more details about my VIC-20 programs.

Life After VIC

I think I only used the VIC for about a year. I had started frequenting a local Radio Shack store while my grandmother shopped next door. I was learning about their TRS-80 Color Computer. It wasn’t nearly as colorful as the VIC, but it had a better BASIC and much more RAM. I made friends with the workers there and they would let me hang out on Saturdays, writing programs or using their TRS-80 Model III and modem to dial in to local Houston bulletin board systems (BBS). I remember they would sometimes save off programs I wrote to cassette to use to demo the machine to other customers.

The salesman I interacted with most there was a man named Don Burr. He had a CoCo himself, and I remember the time he called me to tell me they had just gotten Extended Color BASIC in. He said I needed to come by and see all the new graphics and sound commands it had. When I did, seeing the ability to easily draw a LINE, CIRCLE or PLAY a musical note was magic. Everything on the VIC was done using POKE commands. (I did have the Super Expander cartridge that added similar commands to the VIC, but they were very slow and no one could run any programs you wrote unless they had the cartridge as well.)

Don was able to hook me up with a “CoCo” (expanded to 64K) for $300, and I moved on from the VIC. As part of the deal of getting me a new computer, I had to give all my old VIC hardware and software to my dad. I don’t know what he did with it after that. After that, until recently, I pretty much never looked back. Only with the discovery of my old VIC-20 games am I starting to understand how much I actually did with that machine.

Good times.

Up next: Dissecting some of my very first programs. Will I even remember how they work?